Hey folks, if you’re in the welding game, chances are you’ve heard of external-axis welding robots—those bad boys that take your standard six-axis robot team up by adding extra axes (like positioners, track systems, or rotary tables) to handle bigger parts, faster cycles, and more consistent welds. But let’s be real: even the most reliable external-axis robots throw a curveball sometimes. Over 10 years as a supplier of these systems, I’ve sat in on more troubleshooting calls than I can count, and most of the issues people panic over aren’t nearly as scary as they seem. Today, I’m breaking down the most common problems we see, how to fix them fast, and a quick heads up on when you should call in the pros (hint: that’s when it’s way more than a loose wire). External-Axis Welding Robots
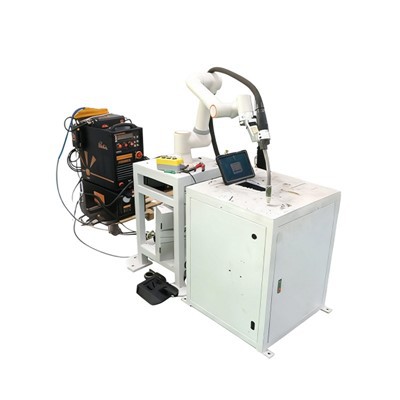
First up: that weird “axis not homing” error that pops up when you turn the robot on. This is hands down the number one call we get every month, and it’s almost never the robot itself being broken. Let’s break it down. Homing is just the robot finding its “zero” position, right? So if it can’t do that, start with the simplest stuff first—we always say “check the cables before you touch the robot.” Half the time, the external axis (say, a rotary table or linear track) has a loose encoder cable that connects it to the robot controller. Maybe a tech tripped over it, or vibration from welding jiggled it loose. Pop the control cabinet open, yank that cable out gently, plug it back in tight, and test again. If that doesn’t work, check the limit switches. These are little safety switches at the ends of the axis’ range of motion, and they get grimey from welding spatter all the time. A quick blast with compressed air (don’t hold it too close! 6 inches away is perfect) to clear spatter and dust off the switch, and if it’s still triggering a false error, wiggle the actuator arm with a screwdriver to make sure it moves freely—sometimes spatter welds it stuck in the “triggered” position. The only time this is a bigger issue is if the encoder itself is fried, which almost always happens from a power surge, not normal wear. Save that for a tech, don’t risk messing with the encoder calibration yourself.
Next: weld seam misalignment that’s getting worse by the day. This is super frustrating, especially because it can kill weld quality and waste a ton of metal. A lot of people immediately jump to reprogramming the robot, but hold up—external axes are the main culprit here, not the robot arm. Start with the axis backlash. Backlash is the tiny gap between gears that makes the axis move a little before it actually starts turning. Over time, from heavy use, that gap gets bigger. How to check it? Simple: move the axis a set amount (say, 100mm) forward, then back, and measure the difference. If it’s more than 0.5mm, that’s your problem. Fixing backlash usually means adjusting the gearbox or lead screw, but a quick band-aid for small issues is adding a little extra distance in your program when the axis moves, so it accounts for that gap. Another common misalignment culprit is belt tension on linear tracks. If the belt is too loose, it slips when moving heavy parts, throwing the axis off. Grab a tension gauge (or even just pluck the belt like a guitar string—if it twangs like a loose string, it’s too loose) and tighten it to the manufacturer’s specs. One trick we teach all our customers is to check this after every part change, because different part weights put different stress on the axis. And don’t forget about the base of the axis—if it’s bolted to the floor and the bolts worked loose, the whole axis can shift a little, which makes seam alignment way off. Just grab a torque wrench and make sure all mounting bolts are at the right torque, that’s an easy win.
Third issue we see all the time: inconsistent weld quality that comes and goes. It might look good one day, then have spatter or porosity the next, and it’s not the welding wire or power source. When this happens with external-axis robots, it’s usually about axis speed and synchronization. External axes work with the robot arm to move the part while the weld is being done, so if the synchronization is off, the weld heat and speed don’t line up. Let’s say you’re welding a round part on a rotary table—if the table is spinning too fast or slow when the robot is feeding wire, the weld will be too hot in spots or too cold, leading to porosity. How to check synchronization? Pull up the controller’s axis sync status screen (every robot has this, it’s not a hidden menu) and see if the axis actual position matches the command position. If there’s more than 0.2mm difference, you need to re-sync the axis. Another big one: gearbox wear on heavy-duty rotary axes. If you’re moving parts over 1,000 lbs, the gearbox takes a beating, and worn gears make the axis move unevenly, which messes up the weld. We tell customers to do a gearbox inspection every 6 months—look for metal shavings in the gear oil, which is a dead giveaway of wear. Top up the oil or change it if it’s dirty, and that usually fixes the inconsistency. Oh, and don’t sleep on the motor cooling fans! If a fan is clogged with spatter dust, the motor overheats, which makes it run unevenly. A quick clean with compressed air monthly will save you so many headaches here.
Fourth: unexpected axis jerks or vibration during operation. This is not just annoying—it’s a safety hazard, and it can wear out parts super fast if you ignore it. Most of the time, this is either a balance issue or a problem with the drive system. If you have a rotary axis with a heavy part, and you didn’t balance it properly when you mounted the part, the axis will jerk when it starts moving. Even a part that looks centered might be off by a few pounds, throwing the balance. How to test? Run the axis at slow speed for a full cycle and watch for where the vibration is worst—if it happens at the same angle every time, that’s balance. You can add small counterweights to the opposite side of the part to fix it, or adjust how you mount the fixturing. Another common jerk culprit is a faulty drive cable or worn drive gear. If the cable has frayed wires, it sends inconsistent signals to the axis motor, making it jerk. Check for frays along the whole length of the cable, especially where it bends around the axis’ moving parts. Worn drive gears, like I mentioned earlier, will also cause jerky movement, so if you see metal shavings or chipped gear teeth, that’s your sign to replace the gears before they break completely and cause more damage.
Now, let’s talk about when you should actually call a pro, because I don’t want you messing up a $50k robot trying to save $200 on a service call. If you’re dealing with persistent encoder errors after checking cables and limit switches, that’s a pro job—calibrating encoders is not a DIY task, and messing it up can throw the whole robot off. If your axis has a catastrophic failure, like a broken lead screw or a burned-out motor, don’t try to take it apart yourself. External axes have precision parts that need to be aligned just right, and a botched take-apart can cost way more to fix than a service call. Also, if you’re noticing strange noises (grinding, clunking, high-pitched whines) that don’t go away after basic checks, that’s a sign of internal wear that needs a professional inspection.
Wait, before I wrap this up, let’s add a quick pro tip from our team that we give every new customer: keep a maintenance log for your external axes. Write down every time you check cables, adjust backlash, change oil, or do any other maintenance. The biggest mistake new owners make is waiting for something to break before they check it. We have customers who do 15-minute checks every week, and they almost never have major issues, whereas customers who go months without checking end up needing emergency repairs that cost way more in downtime than the maintenance would have.
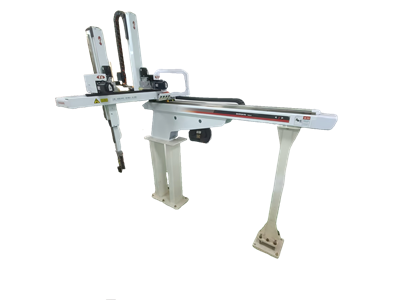
If you’re dealing with any of these issues, or you’re looking to upgrade your welding setup with external-axis robots that actually hold up to heavy use, don’t hesitate to reach out to our team for a no-obligation consultation. We work with shops of all sizes, from small fabricators to big automotive plants, and we can help you troubleshoot whatever’s going on, or find the right system for your needs.
Loading and Unloading Robot References:
- Industrial Robot Association. (2022). Troubleshooting Guide for External Axis Welding Robots. Manufacturing Industry Best Practices Series.
- Miller, J. (2023). Common Failure Modes of Welding External Axes and Preventive Maintenance. Journal of Robotic Welding and Automation, 18(2), 45-52.
- Siemens Energy Automation. (2021). Linear and Rotary Axis Calibration for Robotic Welding Applications. Technical Report TR-RA-007.
- Welding Society of America. (2022). Quality Control Metrics for Robotic Welding Seam Alignment. Welding Journal, 101(9), 67-72.
Dongguan Chuanglida Intelligent Equipments Co., Ltd.
Address: Room 201, Building 2, No. 61, Shachang 1st Road, Dalang Town, Dongguan City, Guangdong Province
E-mail: haoguangli001@outlook.com
WebSite: https://www.boruntestech.com/
